
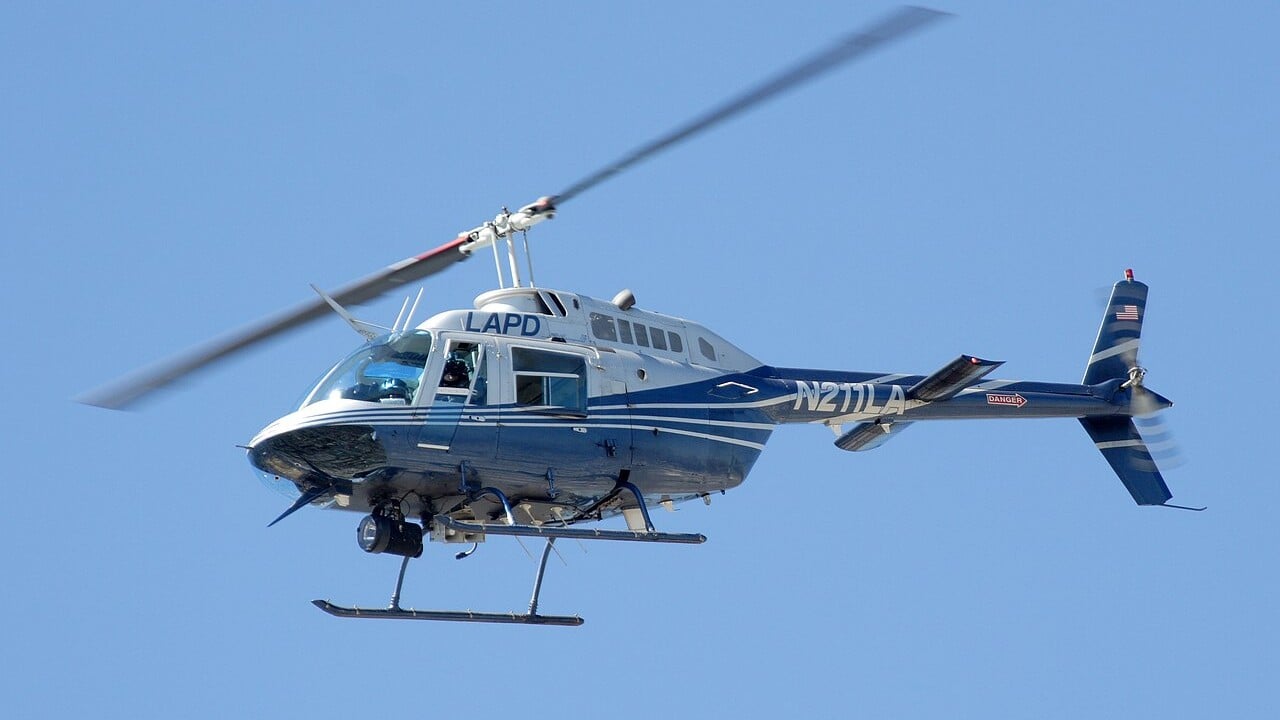
An aeroplane has it easy. Point it down a runway, let the wings do the work, and a few simple controls take care of the rest. A helicopter has to make its own wind. Its wings are the rotor blades, whirling overhead at a few hundred revolutions per minute, and the pilot has to manage them with both hands and both feet at once.
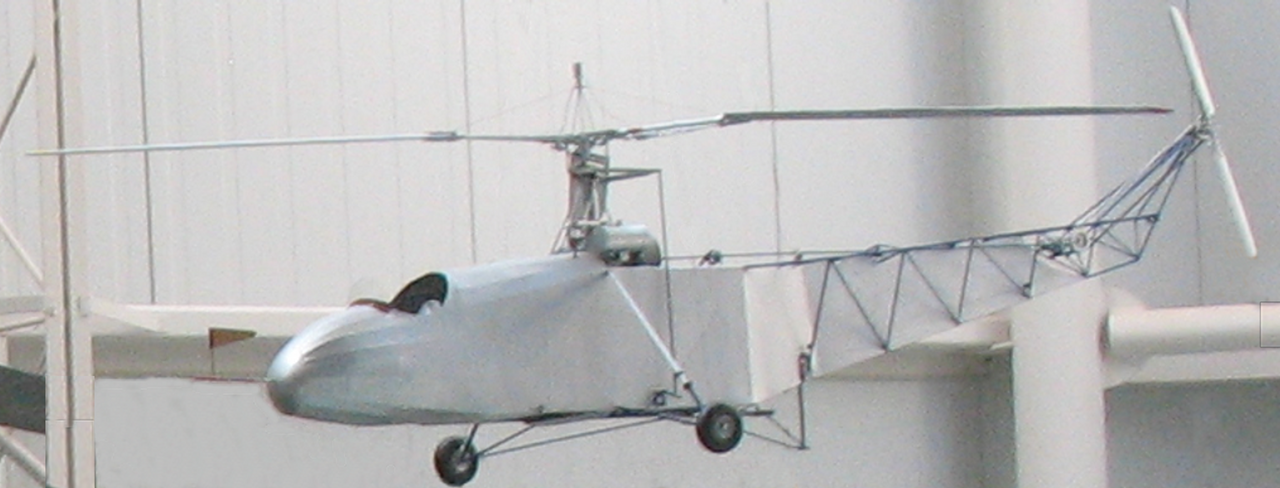
It took a long time to get right. Igor Sikorsky first tried to build a helicopter in Kiev in 1909 and failed. Thirty years later, on 14 September 1939, he lifted his VS-300 a few feet off the ground in Connecticut, and the layout he settled on, a single main rotor with a small anti-torque rotor at the tail, is the one almost every helicopter uses today. Here is how it works.
Datos rápidos
- Main controls: Collective, cyclic and anti-torque pedals, plus the throttle
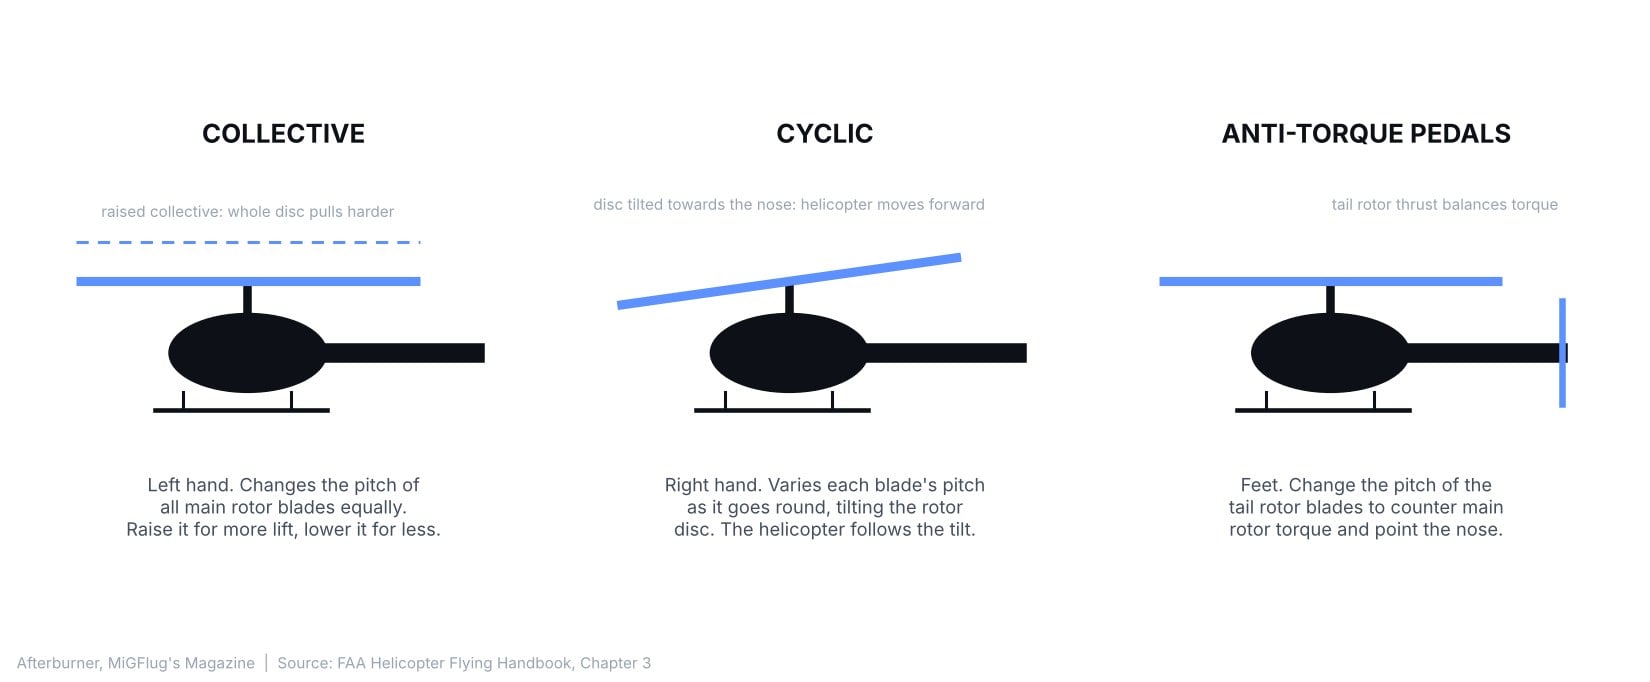
- Collective: Changes the pitch of all main rotor blades equally
- Cyclic: Tilts the rotor disc to move forward, back or sideways
- Pedals: Change tail rotor pitch to counter torque and control heading
- Swashplate: Mechanism that transfers control inputs to the spinning blades
- Layout pioneered by: Igor Sikorsky, VS-300, first flight 14 September 1939
The collective: up and down
The collective lever sits by the pilot's left hand. Raising it increases the pitch angle of every main rotor blade at the same time and by the same amount, which is where the name comes from. More pitch means a higher angle of attack, more lift, and the helicopter rises. Lower the collective and the blades flatten out, lift falls and the helicopter descends.
There is a catch. More pitch also means more drag on the blades, which tries to slow the rotor down, and helicopters need their rotor rpm to stay almost constant. So the throttle, usually a twist grip on the end of the collective, has to add power as the collective comes up. On most turbine helicopters a governor does that automatically. In older piston helicopters the pilot coordinates collective and throttle by hand.
A clear animated walk-through of how a helicopter generates lift and is controlled.
The cyclic: tilting the disc
Between the pilot's knees is the cyclic, the stick that steers. The rotor's lift always acts at right angles to the disc the blade tips trace out. Tilt that disc forward and part of the lift pulls the helicopter forward; tilt it left and the helicopter slides left. The cyclic does the tilting.
It does so cleverly. Rather than changing every blade equally, the cyclic changes each blade's pitch as it goes round: a little more on one side of the disc, a little less on the other. The blade with more pitch climbs, the blade with less pitch drops, and the whole disc tips. Because a spinning rotor behaves like a gyroscope, the response arrives about 90 degrees after the input, so the linkages are rigged to change the pitch roughly a quarter-turn early.
The part that makes all of this possible is the swashplate, a pair of plates around the rotor mast. The lower one does not rotate and is moved by the pilot's controls; the upper one spins with the rotor and passes the movement to each blade through pitch links. Raise the whole swashplate and every blade's pitch rises together. Tilt it and the pitch rises and falls once per revolution.
The pedals: taming torque
Spin a rotor one way and, by Newton's third law, the fuselage wants to spin the other way. That is why a single-rotor helicopter needs a tail rotor. The pilot's anti-torque pedals change the pitch of the tail rotor blades, and therefore how hard the tail rotor pushes. Press the right pedal and the nose yaws right; press the left and it yaws left. In a hover, the pedals are how a pilot turns the helicopter on the spot.
The FAA notes a detail that surprises many people: the tail rotor can also push the other way. That matters in autorotation, the engine-off glide, when transmission drag tries to swing the nose in the same direction as the main rotor. Helicopters with two main rotors turning in opposite directions, such as tandem-rotor designs, cancel the torque and need no tail rotor at all.
A close look at how the swashplate turns stick inputs into blade pitch changes.
Why it took until 1939
Sikorsky's early attempts in 1909 and 1910 used coaxial rotors and could barely lift themselves, let alone a pilot. By the late 1930s he had the engines and the understanding, and United Aircraft gave his team 30,000 dollars to test the single-rotor idea. The VS-300 made its first tethered hop on 14 September 1939, with Sikorsky himself at the controls, and he and other pilots went on to fly variations of it for more than 100 hours. In 1942 the US Army ordered the R-4, America's first production helicopter.
Sikorsky never doubted what the machine was for. Rescue, he believed, was the helicopter's highest calling, and history agreed: a Sikorsky YR-4 flew the first helicopter rescue under combat conditions, in Burma in April 1944.
Next time you watch a helicopter hover, look at the pilot's hands and feet. Left hand on the collective, right hand on the cyclic, both feet on the pedals, every movement affecting the others. It is the most hands-on flying there is.
Micah Muzio's practical explanation of how the controls feel from the pilot's seat.
Sources: FAA Helicopter Flying Handbook (Chapter 3), Lockheed Martin / Sikorsky (VS-300 75th anniversary release, 2014), Igor I. Sikorsky Historical Archives
0 Comments